Sep 2026 – Present
- Leading the technical direction and development of learned autonomy at HIVE, taking heavy industrial machines from teleoperation toward supervised autonomy.
- Hands-on across vision-language-action models, data pipelines and training infrastructure, connecting robot learning research with real-world operations.
- Building toward shared intelligence that learns from real work and transfers across machines, sites and tasks.

Jan 2026 – Aug 2026
- Built Almetra’s (previously Deltia) robotics team from the ground up, alongside Almetra’s co-founder and CTO.
- Architected the perception-to-action stack, connecting industrial video understanding to robotic planning and execution.
- Trained manipulation policies from human demonstrations and robot interaction data, combining diffusion policies and classical control for contact-rich tasks.
- Designed object-centric, cross-embodiment approaches meant to generalise across tasks, environments, and robot platforms.
In this role, Almetra (previously Deltia) was selected for two programs I led the technical work on:

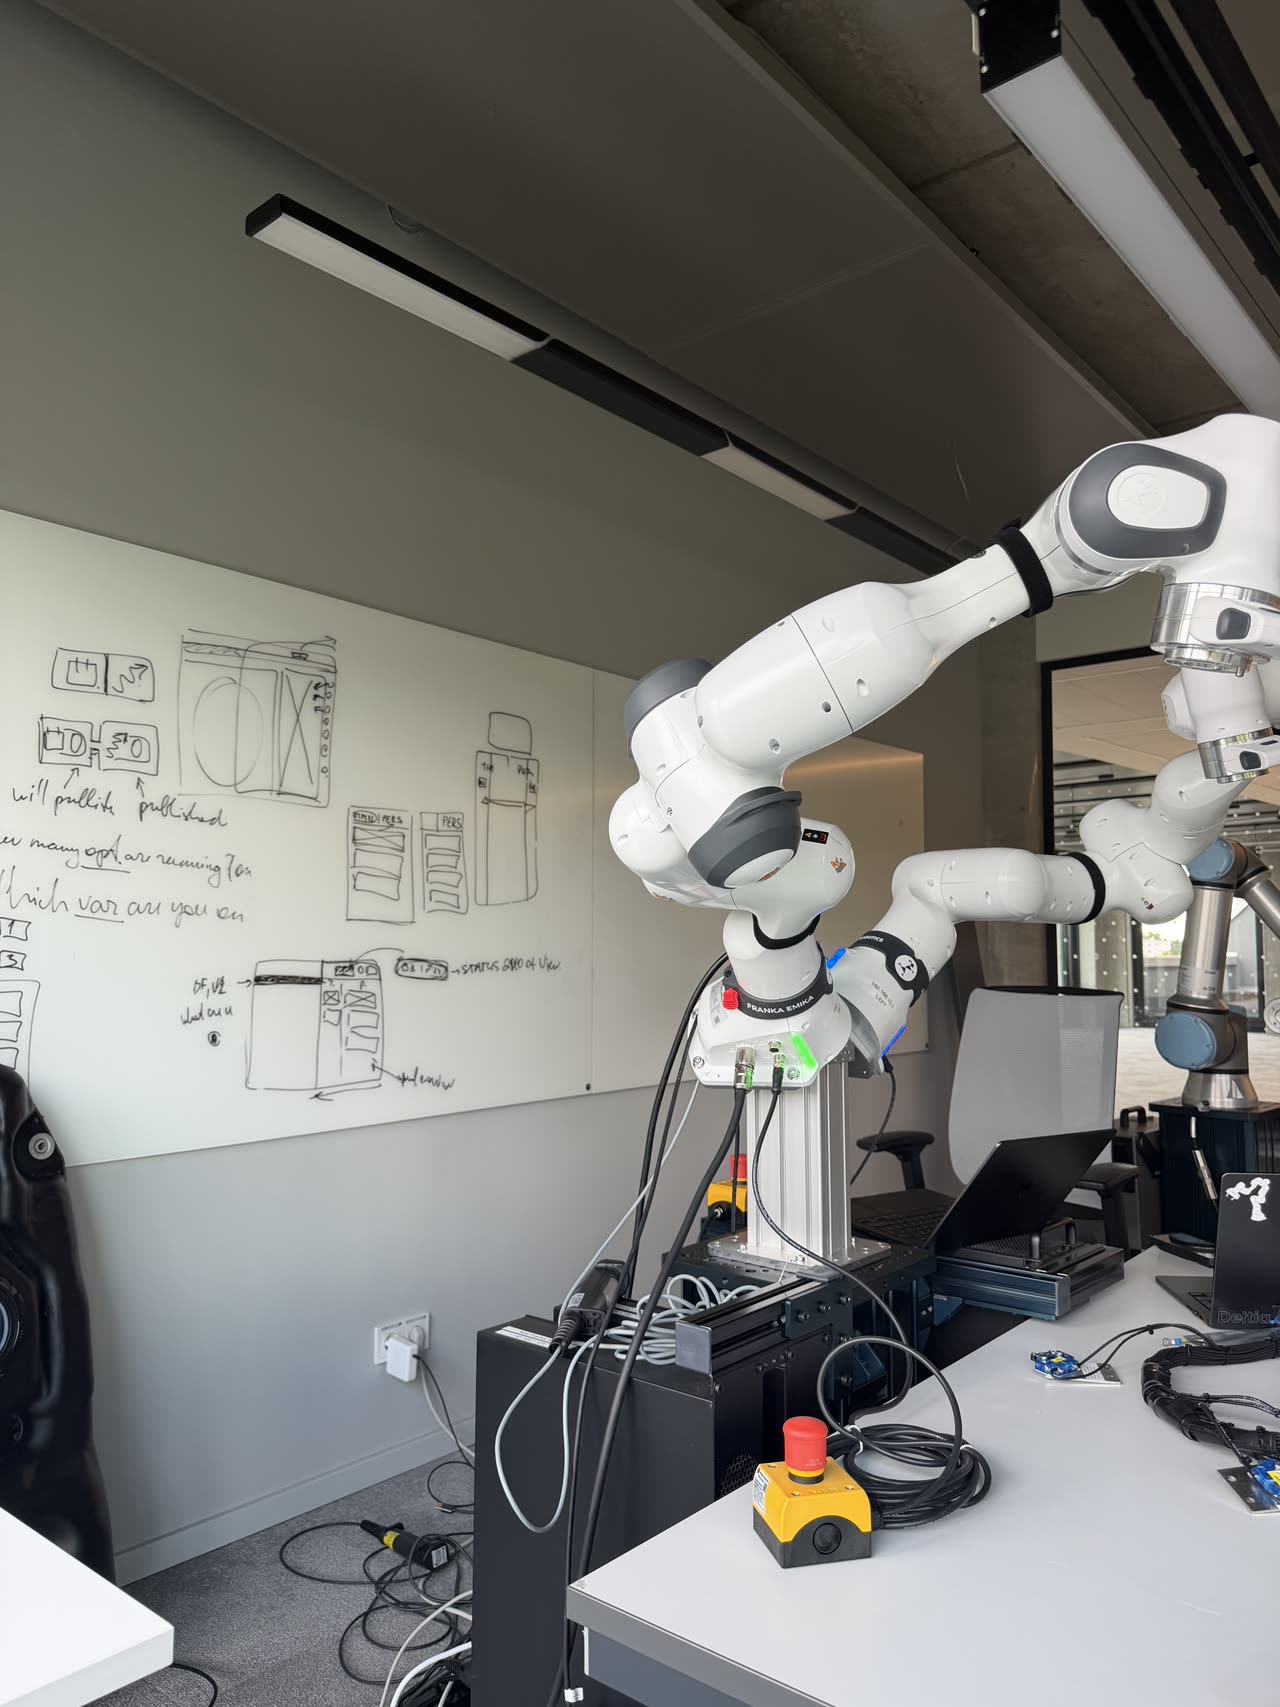
Google DeepMind · Gemini Robotics AcceleratorJun 2026 – Aug 2026Working with the Google DeepMind robotics team to build a physical-intelligence layer that generalises across embodiments, on Franka Research 3 Duo and Universal Robots arms. Pushing VLAs beyond teleoperation data toward video-to-action models and learning from egocentric video.
MassRobotics Physical AI FellowshipApr 2026 – Aug 2026Working directly with the Amazon Robotics and NVIDIA teams on the sim-to-real pipeline. Taking the physical-intelligence stack to real robots: cross-embodiment manipulation policies trained in simulation and transferred to hardware on the NVIDIA Isaac platform, with diffusion policies for contact-rich control and edge-optimised deployment for the factory floor.

Oct 2024 – Jan 2026
- Trained and deployed fine-tuned VLMs in production across 60+ factory sites for customers including ABB, Thermo Fisher, Grundfos, and Bosch, running multi-step action segmentation on live video to recognise activity from short to long horizon at fine granularity.
- Built systems to surface operator actions, workflows, bottlenecks, process variation, and production context from shop-floor video.
- Trained a cross-customer foundational VLM for manufacturing that understands production processes, then distilled compact student models from the teacher for efficient on-station deployment.
- Built on-device LLM agents that read cycle time-series to flag anomalies and summarise efficiency, plus multi-agent internal tools supporting computer vision, robotics, data processing, and annotation workflows.
- Prototyped VLA models via learning-by-demonstration, grounding human demos into action graphs.
- This perception work became the foundation Almetra’s robotics programme grew out of.
Jul 2022 – Sep 2024
Senior Computer Vision Engineer
· BCA UK
· 🇬🇧 UK
- Built a full-stack CV system to automate car inspections, cutting inspection time from ~4 hours to under 90 minutes per vehicle.
- Damage detection, interior classification, a text-to-image diffusion pipeline for rare-case augmentation, and segmentation/depth post-processing.
- Built image and video segmentation for virtual showroom and digital-merchandising workflows, turning raw inspection footage into customer-facing visual assets at scale.
- Designed and deployed the cloud computer-vision infrastructure on AWS that ran all of it in production.
- Production models contributed to a 1.3% complaint rate and higher online-purchase confidence.
Dec 2018 – Oct 2023
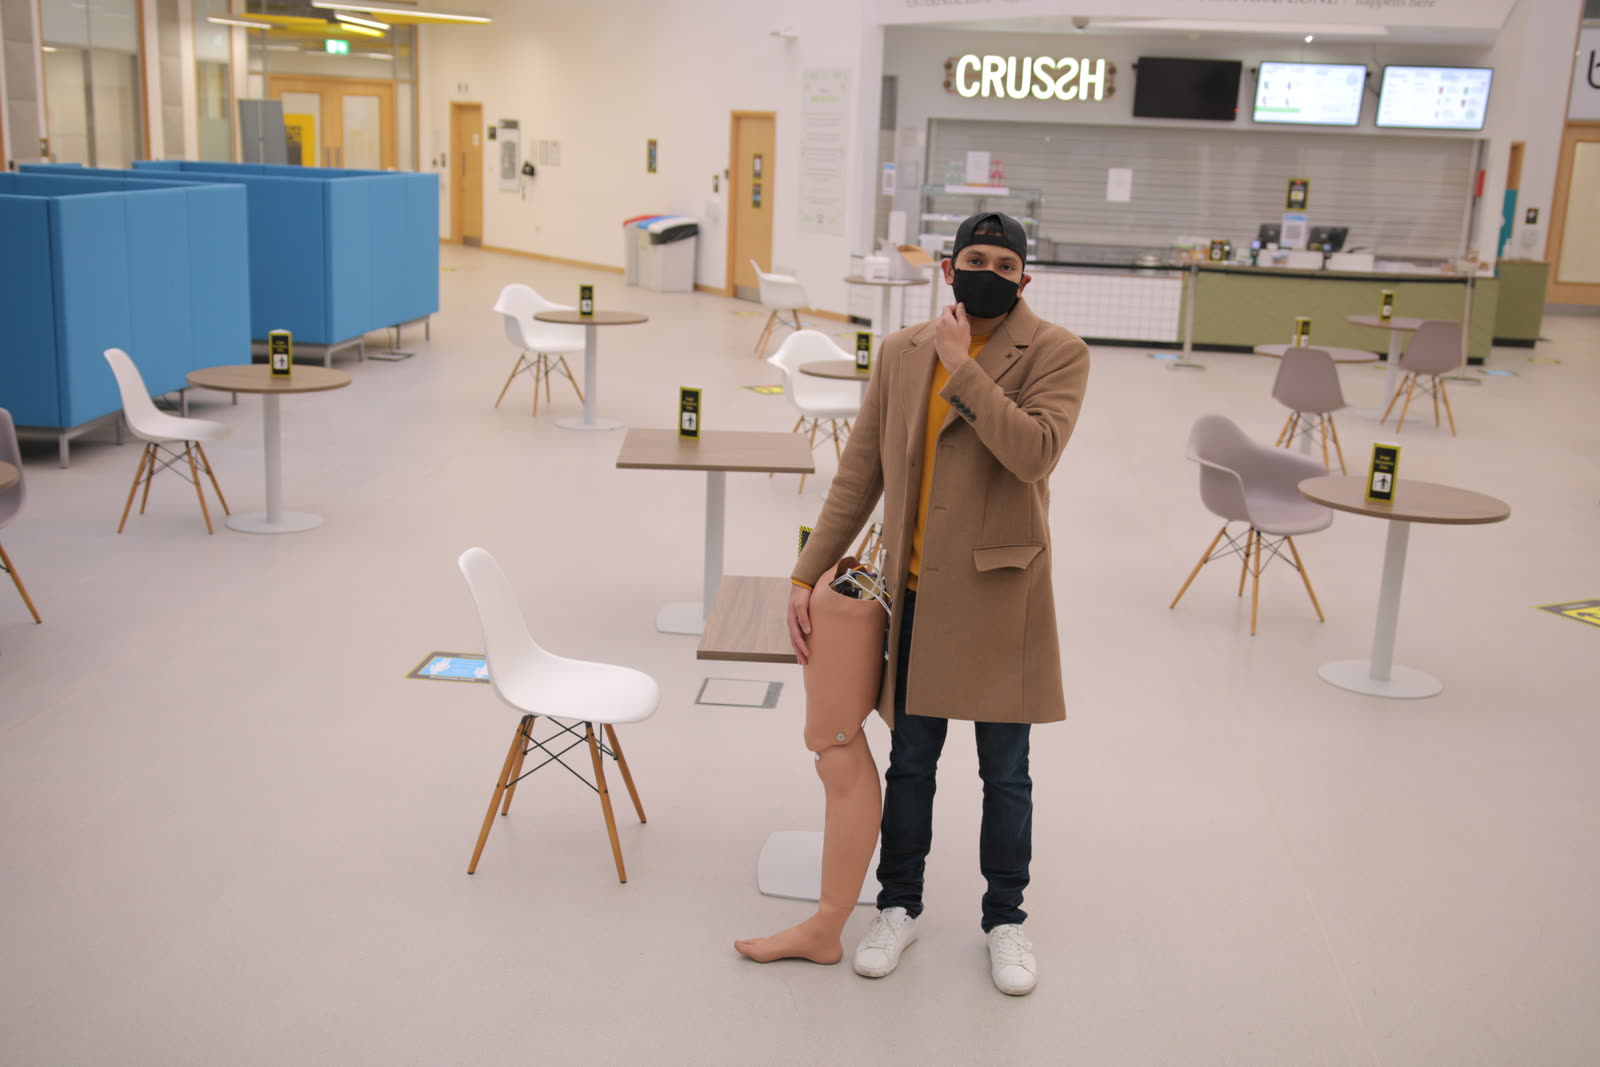
- Founded and led the company end to end, developing an intelligent bionic leg, including performance legs for Paralympic amputees, that understands fit, gait, and movement in real time, with real-time feedback (<50 ms), a custom sensor interface, and integrated thermal imaging for soft-tissue analysis.
- 92% real-time activity classification; validated across 4 NHS trials; built for amputees including a Rio Paralympic gold medalist.
- Led product development across sensing, embedded systems, machine learning, biomechatronics, and user testing.
- Backed by Innovate UK, built on NHS research partnerships, in collaboration with BLESMA and Help for Heroes.
Dec 2018 – Nov 2021
Research Assistant
· Bristol Robotics Laboratory
· 🇬🇧 Bristol, UK
- Engineered the sensor-fusion system inside the prosthetic socket, tracking fit, gait, and physiological change in real time.
- Built a thermal-imaging and machine-learning system to analyse the residual limb’s thermal response over prolonged prosthesis use.
- Ran real-world product trials with an above-knee amputee, evaluating performance, usability, and physiological effect.
Nov 2018 – Jun 2022
Deep Learning Algorithm Engineer, Edge AI
· Q-Free
· 🇬🇧 UK
- Owned a portable embedded camera system for vehicle detection, classification, and tracking across 4/6/8-lane UK and USA motorways (NVIDIA Xavier, Jetson Nano).
- ≥99.7% detection accuracy, 93.5% mAP, ≥65 FPS on NVIDIA Xavier. Deployed across 10 units in the UK and US.
Oct 2018 – Feb 2019
Machine Learning Intern, MedTech
· YU-SCAN
· 🇬🇧 Bristol, UK
- Built a deep neural network to predict symptom severity in multiple sclerosis patients from sensor data on the embedded health-tech device “BEE”.
- Engineered a two-layer SMD sensor board in Autodesk Eagle (with custom component libraries) and a cross-platform React Native app on GCP / Firebase for sensor-data analysis.
- Integrated sensors over SPI, I²C, UART, and Bluetooth, working in an Agile team.
Aug 2018 – Dec 2018
Robotics Sensor Intern
· Bristol Robotics Laboratory
· 🇬🇧 Bristol, UK
- Built a fatigue-monitoring system (a “Fitbit for robots”) that evaluates complex dynamic loads on a robot’s joints.
- Fused sensing with ML/data analytics (LSTM/GBM/SVM; R² 0.94, AUC-ROC 0.93) to decode structural-load patterns for real-time health monitoring and long-term structural integrity of robotic joints.
Mar 2018 – Sep 2018
Computer Vision Intern, Social Robotics
· Bristol Robotics Laboratory
· 🇬🇧 Bristol, UK
- Developed object-recognition algorithms for the TIAGo robot at the European Robotics League 2018 (Social Robots), improving human-robot interaction and task efficiency.
- Added search, person-following, object-moving, and visitor-recognition features for assisted-living environments.
- Ran SLAM (RTAB-Map, AMCL, ROS) alongside the kinematics and path-planning teams for navigation and mapping accuracy.
Jan 2018 – Apr 2018
- Designed intelligent electronic control circuits for a next-generation vertical farming system for micro-green production.
- Engineered and fabricated control boards for ultrasonic foggers, LED lighting, and environmental sensors (humidity, temperature, moisture).
- Collaborated closely with software interns on embedded control.
Education
2020
MSc, Advanced Robotics & Artificial Intelligence
· University of Bristol
· First-Class · Distinction in dissertation
- Focus: robot learning.
- Thesis: an intelligent bionic leg for lower-limb amputees, built with Paralympic athletes in mind.
- Outside the lab, I swam competitively at national level.
Publication
- Customization of a transfemoral prosthetic socket to minimize discomfort for residual-limb volume change. IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), 2023.
Recognition
- Press: BBC Radio 4, Business Leader, Business Live, Business West, Leading Healthcare, Engineering in Business
- Awards: Young Innovators Award 2021 (one of 23 across the UK); SETsquared Breakthrough Bursary; Santander Graduate Entrepreneur Award; Disruptive Startup Finalist (Tata Varsity)
- Collaborations: Google DeepMind, AWS, NVIDIA, MassRobotics, NHS, BLESMA, Help for Heroes